A quick smartphone video
Historically, offline programming (OLP) required a detailed 3D model of the part position, and clamps or fixtures in the cell.
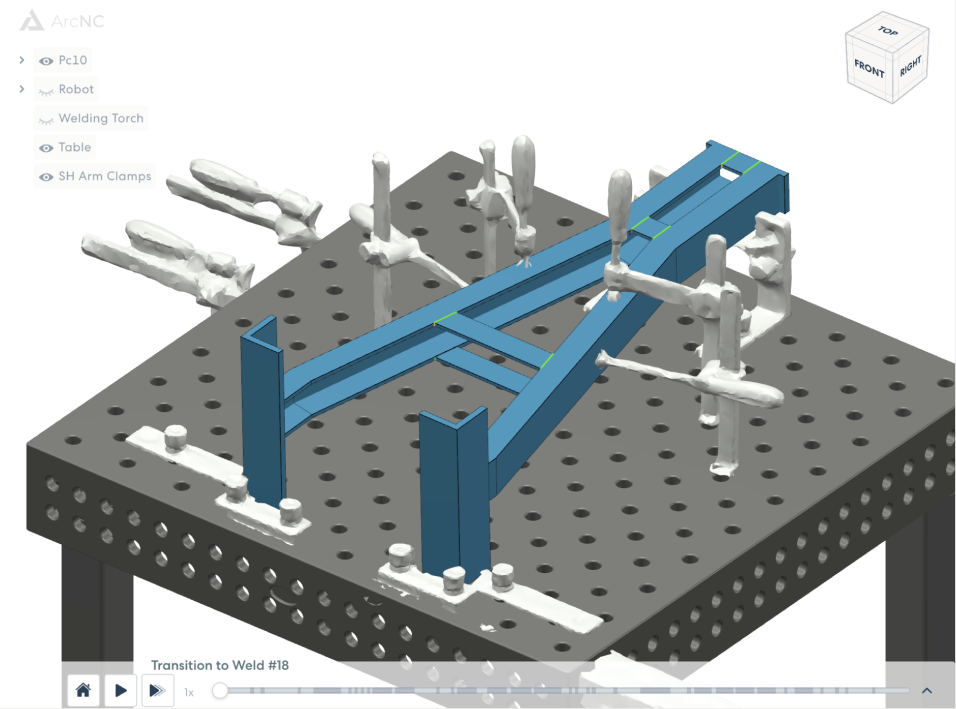
Now, you can just scan the cell with your smartphone, and let ArcNC automatically generate the robot program.
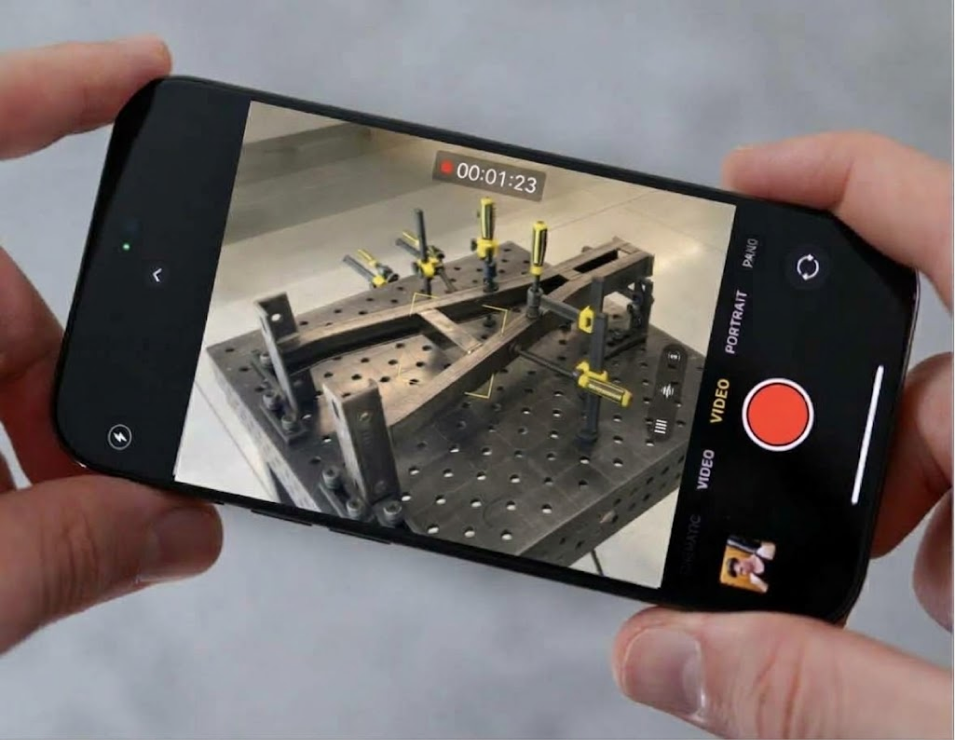
Part positioning
The exact position of the part is extracted from the camera images
Robot motions are calculated automatically to execute all desired weld seams.
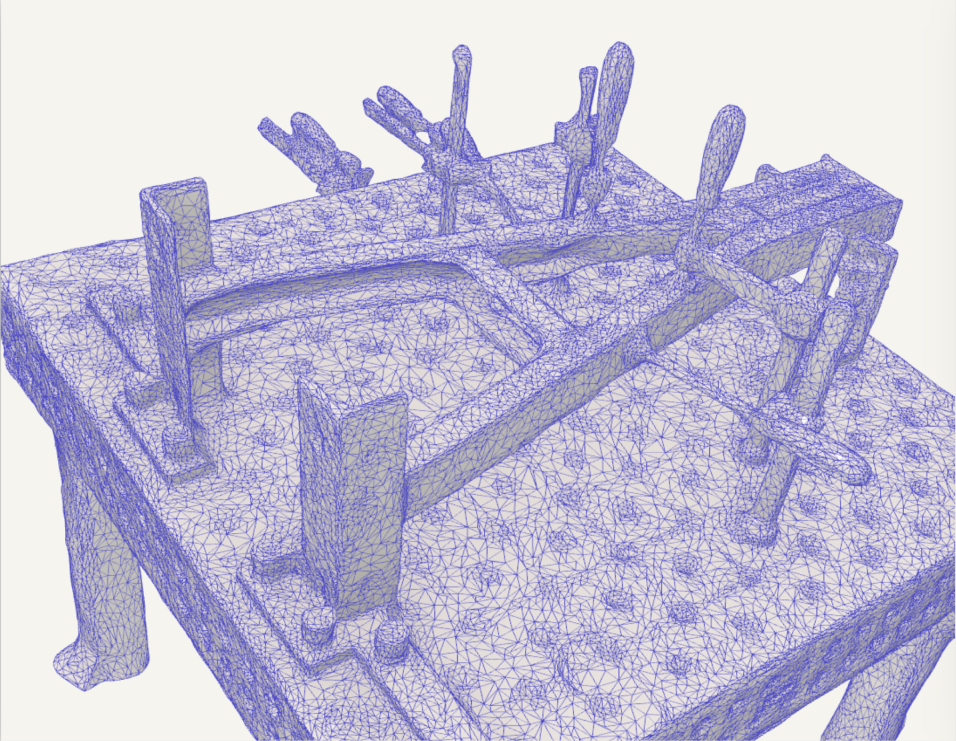
Clamp or fixture geometries
Clamps and fixture geometries are extracted automatically and used to avoid collisions.
The robot will automatically keep a safe distance from all collision geometries.